Foundation Models in Predictive Maintenance: Time Series and Field Physics

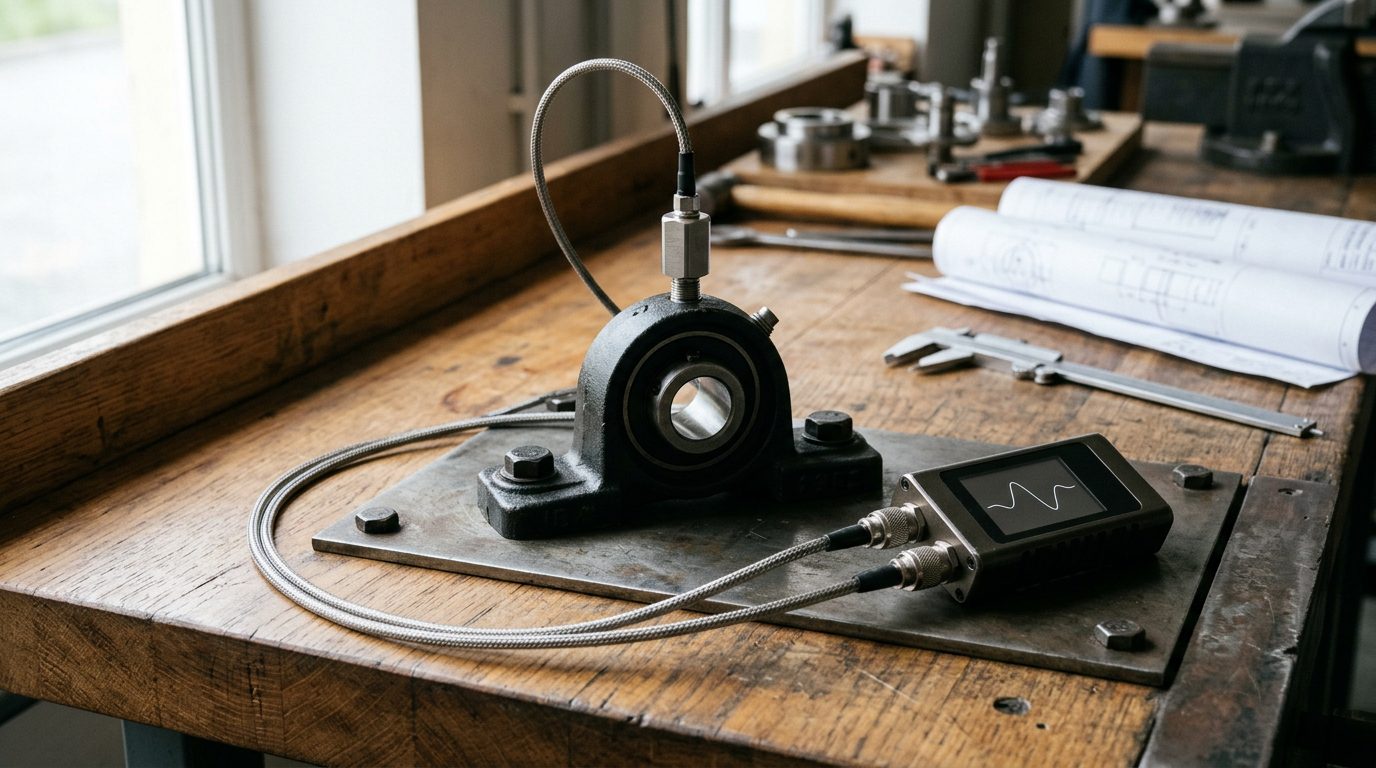
A model’s ability to mathematically project a sensor curve does not mean it comprehends the physical failure mechanics inside the machine.
The transformative impact of large language models on natural language processing has inevitably catalyzed efforts to apply similar transformer architectures to time series data. Pre-trained foundation models such as Google TimesFM have attracted substantial interest due to their zero-shot capability to extrapolate complex temporal curves without requiring extensive custom training. In industrial settings, where predictive maintenance projects traditionally demand months of laborious modeling, this approach promises immediate operational velocity. Yet forecasting e-commerce web traffic or atmospheric temperature trends belongs to a fundamentally different engineering domain than predicting the failure mechanics of a heavy-duty industrial bearing rotating at thousands of revolutions per minute. This analysis evaluates the physical boundaries of predictive maintenance, from bearing fault frequencies and resonance behaviors to multivariate process context and safety-critical margins, defining the proper role of foundation models on the plant floor.
The Chasm Between Statistical Curve Fitting and Failure Physics
Large language models excel at resolving word order, semantic context, and structural language patterns. When analogous transformer models are applied to time series data, the system treats sequential data points as numerical tokens, calculating the statistical probability of where the curve will travel next. For macro-level trends such as regional energy demand or financial indexes, this extrapolation often yields valuable predictive utility.
On the factory floor, however, an equipment failure is never an abstract mathematical deviation on a line chart. A mechanical or electrical fault is the direct, deterministic consequence of underlying physical laws:
- A microscopic fatigue spall on the inner ring of a bearing generates sharp, cyclical shock impacts each time a rolling element passes over the defect, producing identifiable fault frequencies.
- Shaft misalignment, rotor unbalance, or structural resonance creates harmonic vibration peaks directly proportional to rotational operating speeds.
- The onset of pump cavitation produces fluid vaporization and microscopic bubble collapse, releasing high-frequency acoustic noise and wideband vibration energy.
These phenomena are governed by mechanical dynamics and material degradation, not statistical trends. A general-purpose time series foundation model can readily identify an unexpected increase in overall vibration amplitude; however, it possesses zero intrinsic physical awareness to determine whether that increase stems from a structural resonance pass, a temporary operational load shift, or catastrophic inner raceway spalling.
Field Constraints: Why a General Foundation Model Falls Short
Three primary operational realities illustrate why pre-trained statistical models cannot independently govern industrial predictive maintenance:
- Multivariate Process Context: In laboratory benchmarks, time series algorithms are frequently evaluated on isolated, single-sensor datasets. In actual manufacturing environments, no sensor exists in isolation. When an induction motor exhibits elevated vibration, an accurate diagnosis requires correlating that signal against motor current draw, grid frequency, ambient temperature, and instantaneous production load from the SCADA system. A sudden vibration surge may indicate mechanical degradation, or it may simply reflect increased slurry viscosity or a rapid speed ramp. Divorced from process context, a statistical model either flags false alarms during routine operating shifts or fails to detect severe faults masked by low load conditions.
- Rare Events and Extreme Class Imbalance: Foundation models rely on trillions of web tokens because digital text is abundant and accessible. Industrial machinery operates in stark contrast: equipment runs within nominal operating parameters for the vast majority of its lifecycle. High-impact catastrophic failure events such as turbine blade fracture or compressor lock-up are exceedingly rare, yielding minimal labeled data. A model trained primarily on broad statistical patterns lacks exposure to localized physical failure modes and cannot reliably identify the specific mechanical degradation trajectory without physical verification.
- Safety-Critical Tolerances and False Alarm Costs: In consumer recommendation systems, an accuracy rate of eighty-five percent is often celebrated, as a poor recommendation carries negligible operational impact. Industrial production tolerates no such margin:
- False Positives: When an algorithm incorrectly flags healthy machinery as defective, plant managers face costly unplanned line shutdowns, unnecessary technician deployments, and severe output loss. After several phantom alarms, maintenance crews lose faith in the system and silence monitoring alerts entirely.
- False Negatives: When a model overlooks subtle early-stage mechanical degradation, the result is catastrophic equipment failure, substantial capital replacement costs, and severe personnel safety hazards.
The Real Value of Foundation Models: Operational Velocity
These structural constraints do not render time series foundation models irrelevant in industrial engineering. On the contrary, when properly scoped, they eliminate the most significant bottleneck in condition monitoring projects: initial deployment latency and engineering overhead.
Traditional predictive maintenance initiatives demand extensive, multi-month development cycles:
- Collecting historical sensor records, cleaning outlier telemetry, and reconciling asynchronous timestamps
- Engineering hand-crafted signal features across time and frequency domains
- Selecting and benchmarking legacy architectures such as ARIMA, LSTM, or gradient boosting
- Conducting hyperparameter tuning and extensive on-site validation trials
This overhead presents an insurmountable barrier for industrial plants lacking dedicated data science and signal processing departments.
Pre-trained time series models act as an effective force multiplier in this setting. Without requiring bespoke training from scratch, they instantly identify baseline shifts and obvious trend divergences. They compress proof-of-concept timelines from months to days, providing a dependable anomaly screening filter that validates data pipeline integrity across hundreds of monitored assets.
Comparative Architecture of Both Approaches
The core engineering distinctions between purely statistical foundation models and physics-based field analytics are outlined below:
| Dimension | Statistical Foundation Models | Physics-Based Field Analytics |
|---|---|---|
| Primary Approach | Numerical curve projection and pattern recognition | Vibration spectrum, harmonic analysis, and thermodynamics |
| Data Requirements | Raw time series telemetry without physical metadata | Kinematic specifications, shaft RPM, bearing geometry |
| Deployment Time | Hours to days utilizing pre-trained architectures | Weeks to months requiring physical sensor calibration |
| Diagnostic Capability | Highlights trend anomalies without identifying root causes | Pinpoints specific defective components such as inner rings or gear teeth |
| Process Context | Susceptible to false alarms during load and speed transitions | Normalizes vibration limits dynamically against operational speed |
| System Role | High-throughput trend screening and anomaly triage | Authoritative safety-critical decision-making and work order scheduling |
Engineering Architecture: A Hybrid, Layered Approach
Presenting artificial intelligence as an infallible autonomous intelligence is as flawed as completely dismissing its utility from industrial operations. Sound systems engineering positions foundation models not as autonomous maintenance arbiters, but as rapid analytical screening engines.
A resilient industrial monitoring architecture implements a clear division of responsibility:
- Edge Layer and Signal Processing: High-frequency accelerometer signals are processed locally on ruggedized edge compute. Fast Fourier transforms extract vibration spectra, isolating specific kinematic bearing fault frequencies before transmission.
- Rapid Trend Engine: A pre-trained foundation model scans across hundreds of asset telemetry streams simultaneously, filtering out seasonality and operational noise to flag meaningful shifts requiring engineering attention.
- Physical Verification and Decision Engine: Detected anomalies are cross-referenced against SCADA process variables, including motor rotational speed, hydraulic pressure, and thermal limits. Deterministic, rule-based systems and certified reliability engineers verify whether the deviation represents genuine component fatigue or standard operating variance before initiating work orders.
Through this layered architecture, foundation models reduce computational and engineering bottlenecks, while mechanical physics and field domain expertise remain the final line of defense protecting plants from unplanned downtime.
Conclusion
Algorithmic sophistication cannot bypass the uncompromising mechanical reality of the physical world. In industrial condition monitoring, genuine value is not generated by deploying the largest neural network, but by engineering a reliable diagnostic pipeline tailored to the physical failure mechanisms of the asset.
Time series architectures like Google TimesFM represent powerful tools for accelerating deployment cycles and lowering the barrier to predictive maintenance. However, when critical maintenance decisions must be executed, vibration signals cannot be parsed like language tokens. They must be evaluated as metal fatigue, lubricant breakdown, and micron-level bearing wear.
No algorithm that ignores the laws of physical mechanics will long survive on the factory floor.
📚 References
Das, A., Kong, W., Leach, A., Mathur, S., Sen, R. and Yu, R. (2023). A decoder-only foundation model for time-series forecasting. Google Research, arXiv:2310.10688.
Randall, R. B. (2011). Vibration-based Condition Monitoring: Industrial, Aerospace and Automotive Applications. John Wiley & Sons.
Mobley, R. K. (2002). An Introduction to Predictive Maintenance. Butterworth-Heinemann.
📋 Related Links
🔗 Engineering Ego and Field Reality: Why Elegant Architectures Fail at Customer Bottlenecks
🔗 Deterministic Behavior: Real Time, Real Results